SARCTRAC Mk5
Satellite Antenna Rotator Controller and TRACker
(This page is currently under construction)
Introduction
For several years we were content to set up our portable SARCTRAC system whenever we wanted to work satellites. However, for a permanent installation, we needed a heavy-duty rotator which could handle a 1.8m parabolic dish or couple of cross-polarised Yagi antennas. Based on the success of SARCTRAC Mk4, we have value-engineered the solution to reduce the cost of rotator construction and we now publish the full construction details and the software for those who wish to copy our design or seek inspiration for their own designs.
This SARCTRAC Mk5 rotator, together with our SARCTRAC Earth or SARTCTRAC Space software, and our new Deep Space Ground Station forms a fully-integrated, heavy-duty, home satellite or spacecraft tracking system.

SARCTRAC Mk5 CAD Model
SARCTRAC Mk5 was designed entirely in FreeCAD. The software was written in Python and runs on a Raspberry Pi Zero 2W. We cut and machined all the Aluminium stock ourselves in the garage, using nothing but a cut-off saw and a drill press, although, we had some help from John at Lightning Laser Cutting to cut the six panels for the cover.
The general arrangement and the names of the main components are shown in the following diagram.

Component General Arrangement and Nomenclature

FreeCAD Development (TBD)
(TBD)
Software Development
Video (TBD)
Components
The main task for us with SARCTRAC Mk5 was to try to reduce the overall cost of the components. to make it more affordable for schools and young people. For SARCTRAC Mk4 we used all high-quality, bespoke components.
We performed a detailed, value-engineering task with the following cost-cutting outcomes:
- We found that buying the motors, gearboxes and drivers as a bundled set from general market sites was a huge saving.
- We replaced the bespoke aluminium saddle, shaft hubs and mast platform with heavy-duty, galvanised-iron angle brackets from the hardware store.
- We replaced the bespoke keyed gearbox shafts with cut lengths of stainless steel M14 threaded rod.
- We replaced the Hall-effect index switches and magnets with end-stops and some smarter software
In all, we saved about 30% of the overall cost.
These right-angle worm gearboxes are amazing. They are used for both the azimuth and elevation shafts. They have a single 11mm keyed input and a double 14mm keyed output. They have a flange to directly fit a NEMA 23 stepper motor on the input. We chose the 80:1 gear ratio. They have a max torque of 1.7 kg.m and a max radial load of 128 kg.
Now this is probably an overkill, but we know that despite our best efforts water will eventually get in. The input and output hollow shafts of this gearbox do not look like stainless steel to us. They could be mild steel. So, just a precaution, we coated them - and just about everything else in this project - with Tef-Gel. We love it because, unlike grease, it keeps everything from corrosion.

NMRV30 (57mmx57mm motor flange with 80:1 gear reduction) Thru-Shaft Worm Gearbox
To reduce cost we use M14 stainless steel threaded rods for all output shafts. These rods are are not keyed so we drill and insert 5mm x 8mm roll pins as keys and we tighten the bolts onto the hollow gearbox shafts using nuts and washers to achieve a solid fit.
The azimuth shaft is mounted vertically and would normally take the full weight of the rotator and antenna assembly. Care must be taken to ensure that axial forces on this shaft are not transferred to the gearbox bearings. Instead, careful fitment of a thrust bearing and packing washers around this shaft ensures that any axial force is transferred to the gearbox housing.
(TBD)
M14 Bolts used for Gearbox Shafts
This is the thrust bearing to take the vertical load of the rotator and antenna assemblies. It comes in three parts: Two ball-race rings with different inner-diameters and a ball-bearing assembly. The smaller inner-diameter ball-race ring is mounted on the top in this application. The ball-bearing assembly is packed with grease prior to assembly.
To make the thrust bearing to take all the vertical load it must be stacked with four large flat washers to be the same length as the vertical shaft. The shaft itself is free to move up and down inside the key way. The circlip on the shaft must also be free so as not to take any load. These M30 stainless steel washers have the same outside diameter as the thrust bearing and have a large-enough inner diameter to take the shaft.
The thrust bearing itself was housed in short piece of PVC pipe, secured to the azimuth gearbox housing with silicone sealant. A small gap at the bottom is required to permit rotation of the rotator assembly. While it is not perfectly sealed, it should prevent ingress of some rain and dust. It will need to be inspected every few years or so.

51206 Thrust Bearing

M30 x 56mm x 3mm Flat S/S Washer
These are NEMA 23, 2-phase stepper motors are 112mm long, have a holding torque of 2.8 N.m, a rated current of 3.0 A and a step angle of 1.8 degrees. That is 200 steps per revolution. The output shaft is 8 mm diameter with a flat key.
We designed for a maximum rotator speed of 2.0 RPM so, with a 400 microstep-per-rev controller and an 80:1 gearbox, the maximum motor speed will be 320 RPM, running at 1066 steps per second.

57BYG250H-8 NEMA 23 Stepper Motor
Stepper motors, of course, can only provide relative positioning from a known starting point. The high-torque motors and high gear-ratio gearboxes ensure that the motors do not skip a step during operation. In SARCTRAC Mk4 we used Hall-Effect magnetic switches to provide an indexing signal when the rotator was in the North/Horizontal position. For SARCTRAC Mk5 we use a more accurate photo-interrupter disk, with a small index slot, mounted on the rotating gearbox shafts. A photosensor is mounted on the stationary gearbox housings. The Microcontroller software uses these sensors to store the North/Horizontal reference position and the gearbox backlash measurement in non-volatile memory. A one-off script is run initially to calibrate the rotator. Thereafter, if the rotator power is suddenly cut off, The Microcontroller automatically stops and saves any offset of the reference position in flash memory. In this way the rotator always knows where it is pointing.

Photosensor

Photo-Interrupter Disk and Photosensor
These DM542 stepper motor drivers are great. They handle up to 4.2 A from 20-50 V. Which is good, because we decided to run the stepper motors off 48 V DC to keep the current down and the performance up. They have opto-isolated step and direction control inputs, which work down to 5 V. So a 3.3 V to V 5 level converter is also required for the 3.3V Microcontroller. The main reason for using these devices is the intelligent idle current reduction, which keeps the motors cooler. The minimum rate for this driver is 400 microsteps per rev.

DM542 Stepper Motor Driver
Of course we needed a 48 V power supply for the stepper motors. This power supply will be located inside the house, providing safe, low voltage to the rotator outside. It will be housed in a suitable enclosure.

S-400-48 48 V DC Power Supply
The rotator electronics devices include:
- Two DM542 stepper-motor drivers
- A Veroboard electronics assembly comprising:
- A Elecrow W5 Microcomputer
- A 48 V to 5 V DC/DC converter
- A 5 V to 3.3 V logic level converter
- A 48 V opto-isolated, power supply detect circuit (which is used to to save the rotator position prior to power-down)
- A 5 GHz external WiFi antenna and cable
- Two Photosensors
All the electronics devices are mounted inside the rotator laser-cut enclosure.
The rotator Microcontroller is an Elecrow Pico W5 which is compatible with a Raspberry Pi Pico 2W, except it has a 2.4/5 GHz WiFi module.
Since the rotator is housed inside a metal enclosure, you need to modify the Microcontroller to connect it to an external antenna. This involves some precision, surface mount soldering of a U.FL coaxial connector to the board. The external WiFi antenna has an SMA connector for mounting the antenna on the enclosure and a short cable terminated with a U.FL connector for connection to the Microcontroller.

Elecrow Pico W5

2.4 / 5 GHz WiFi Cable and Antenna
The main feature of these XL7015 adjustable DC/DC converters is that they can handle an input voltage of up to 80 V. The unit is set to 5 V to provide power to the Microcontroller and the photosensors.

XL7015 DC-DC Converter Step-Down Module 5V-80V Wide Voltage Input
Downloads
SARCTRAC Mk 5 FreeCAD files can be downloaded from here (TBD) (51MB. Includes 23 Drawings. Last updated 28 May 2024).
SARCTRAC Mk 5 Parts List file can be downloaded from here (TBD) (15kB Excel format. Last updated 17 May 2024).
SARCTRAC Mk 5 Software and installation guide can be downloaded from here (TBD)
These files are provided as-is, without any warranty and may not be fit for any purpose whatsoever. They may be change at any time without notice. No support is provided. No responsibility is accepted. Prices shown are indicative only. No suppliers are endorsed. The main project file is SarctracMk5.FCStd.
Assembly
(TBD)
Software
The rotator control and communications functions are provided by microcontrollers, using software written in MicroPython. The system comprises a SARCTRAC Server, running inside the rotator, and a SARCTRAC USB WiFi Dongle connected to a PC. These processors provide a dedicated WiFi link for communications between the PC and Rotator. The SARCTRAC Server has a WiFi Access Point and Telnet Server, a command interpreter and a stepper motor position and speed controller. The SARCTRAC USB WiFi Dongle has a WiFi Client and Telnet Client. The rotator can be controlled via a simple user interface using a serial terminal, such as PuTTY running on the PC. However, the rotator also transparently accepts AMSAT EasyCommII protocol commands from a tracker program also running on the PC.
Further details (TBD)
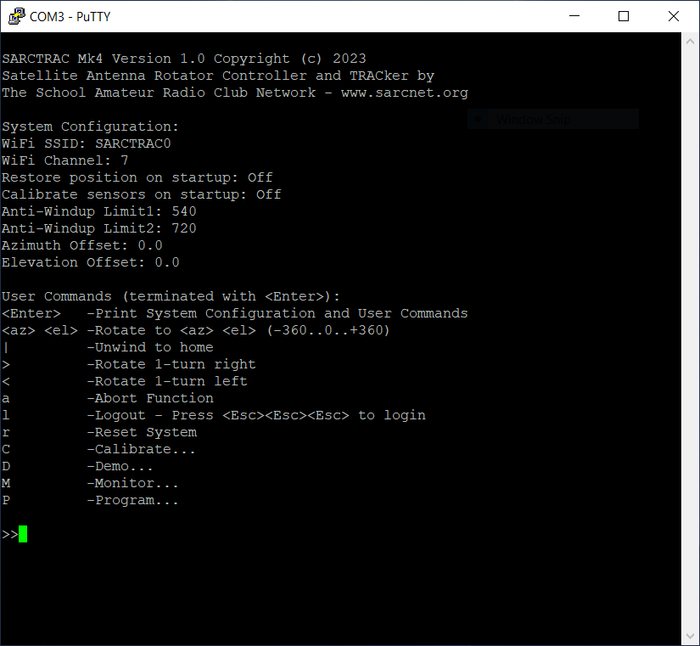
SARCTRAC Access via a serial terminal program
SARCTRAC Software
SARCTRAC Mk1 and Mk2 used to have their own integrated web servers and tracker applications. By popular demand, SARCTRAC Mk3 was able to use any third-party, external tracker. However, for SARCTRAC Mk4 and Mk5, we decided to build a completely new tracker, from scratch, in Python.
We have developed two different versions of SARCTRAC Software:
- SARCTRAC Earth - Satellite Antenna Rotator Controller and TRACker
- SARCTRAC Space - Spacecraft Antenna Rotator Controller and TRACker
History
We first introduced our free, Arduino-based, "Mini Satellite-Antenna Rotator" in 2015. It was a great success, with over 1000 radio enthusiasts from around the world building one. Unfortunately, sourcing the correct components, compiling and uploading the software and calibrating the sensor was too much for many who attempted building it. Let alone the pitfalls of setting up and using third-party, satellite-tracking software. And, as much as we love helping our readers out, we realised that we were spending more time supporting them than developing new projects for the kids.
We partly solved that problem by designing an integrated satellite tracking system that just works: SARCTRAC Mk1 took us over 15 months to develop and was the second generation of our 3D-sensor based antenna rotator. It was half the size of the original unit with many new features. SARCTRAC Mk1 was offered as a DIY kit with all the parts and software required. Unfortunately, it only supported one type of radio: The Yaesu FT-817 and was only suitable for the experienced builder. So, we were still confronted with a large support effort.
In 2021, we produced SARCTRAC Mk3a. We totally revised the project addressing many user, hardware, software, integration, production and support issues: Most readers just wanted the cheapest-possible, AZ-EL rotator to steer their hand-held satellite antennas and to use it with their own PC-based, satellite tracking and radio control applications. Quite a few had problems configuring SARCTRAC Mk2 to connect to their home WiFi network. They wanted a dedicated, wireless solution that did not require the use of a WiFi router. Some had problems when the cables got wound up. They needed a fool-proof safety cut-off device. SARCTRAC Mk2, with a built-in Raspberry Pi 3B+ tracker and web-server, required a lot of power, a large heatsink and was noisy on the VHF/UHF satellite bands. So, we went back to basics and designed a cheap, low-power, low-noise, rotator, with a dedicated wireless link, that would work with popular, many free, PC-based, satellite-tracking applications.
In 2023, we abandoned production of SARCTRAC due to on-going supply and support problems. We realised that our mission was actually getting kids into radio and electronics and not selling rotators. However, we continued development of SARCTRAC for our own use, specifically a heady-duty model we called SARCTRAC Mk4. We designed it entirely in FreeCAD and built our first prototype in January 2024.
In 2026, we value engineered SARCTRAC Mk4 to keep the construction costs down. The result was SARCTRAC Mk5, which can handle a 1.8m parabolic dish or a couple of large circularly-polarised Yagi antennas.
Setup
Features
- Automatically rotates a satellite antenna under the control of a PC-based, satellite tracking application.
- Can be remotely controlled by popular, (mostly) free, Satellite Tracking applications on a Windows or Linux PC, Laptop, Raspberry Pi etc.
- Includes a dedicated WiFi USB dongle - Wireless remote control up to 30m/100ft away.
- Built in WiFi Access Point - No WiFi router or hotspot required.
- Emulates AMSAT EasyCommII rotator protocol – Steers antenna and provides antenna position feedback
- Tested with PstRotator™, Gpredict™, SatPC32™ and Orbitron™. Others TBA.
- Built-in serial terminal utility for manual user control, debug, monitoring, calibration, configuration and simulation.
- Built in microcontroller - Low noise, fast start up and no shutdown procedure required.
- Provides an intelligent anti-windup algorithm - Automatically unwinds the cables between passes.
Links
Specifications
- WiFi mode: 802.11b/g/n. WiFi band: ISM2.4GHz. WiFi range: 30 m (100 ft) typical.
- Rotation range: Azimuth +/-360 degrees. Elevation -30 to 150 degrees.
- Rotation speed: 2 RPM (12 degrees per second) azimuth and elevation.
- Rotation torque: 1.7 kg.m
- Rotation load: 130 kg.m
- Rotation accuracy: < +/- 0.1 Degrees
- Rotation mode: Shortest-path with configurable anti-windup algorithm.
- Start-up time: (TBD) seconds. No shutdown time required.
- Rotator emulation - Serial protocol: AMSAT EasyCommII with position feedback - 9600/N/8/1.